Part 11 |
Detailed Technical Explanation of RFID-Enabled Barcode Label Printers |
11. Mechanical Architecture, Motion Control Systems, Precision Mechanics, and Industrial Build Engineering |
1. Introduction to Mechanical Systems in RFID Printers |
1.1 Importance of Mechanical Engineering |
While RFID-enabled barcode label printers are often viewed as electronic systems, their performance depends heavily on mechanical precision. |
Mechanical subsystems control: |
1. Label movement |
2. Printhead positioning |
3. RFID encoding alignment |
4. Ribbon tension |
5. Cutting mechanisms |
6. Sensor positioning stability |
Even small mechanical errors can cause: |
1. RFID encoding failure |
2. Barcode misalignment |
3. Label jams |
4. Reduced throughput |
5. Printhead wear |
6. RF misalignment |
|
1.2 Mechanical vs Electronic Integration |
Modern RFID printers are tightly integrated mechatronic systems combining: |
1. Precision mechanics |
2. Embedded electronics |
3. Firmware control |
4. RF engineering |
5. Thermal systems |
This integration is essential for synchronized print-and-encode operation. |
|
2. Core Mechanical Architecture |
2.1 Main Structural Frame |
The printer frame provides: |
1. Structural rigidity |
2. Vibration resistance |
3. Alignment stability |
4. Load distribution |
Industrial RFID printers often use: |
1. Die-cast aluminum frames |
2. Steel reinforcement structures |
3. Composite rigid housings |
|
2.2 Mechanical Layout Zones |
Typical RFID printer layout includes: |
1. Media input zone |
2. Media transport zone |
3. Print engine zone |
4. RFID encoding zone |
5. Cutting or dispensing zone |
6. Media output zone |
Each zone must remain mechanically synchronized. |
|
2.3 Precision Alignment Systems |
Alignment systems ensure: |
1. Printhead alignment |
2. RFID antenna alignment |
3. Sensor positioning accuracy |
4. Media path consistency |
|
3. Media Transport System |
3.1 Media Feed Mechanism |
The media feed system moves labels through the printer using: |
1. Drive rollers |
2. Platen rollers |
3. Guide rollers |
3.2 Stepper Motor Control |
Stepper motors are commonly used because they provide: |
1. Precise movement control |
2. Repeatable positioning |
3. Reliable torque output |
Each step corresponds to a controlled movement of the label media. |
3.3 Servo Motor Systems |
High-performance RFID printers may use servo motors for: |
1. Higher speed operation |
2. Closed-loop feedback |
3. Smooth acceleration control |
3.4 Roller Design Engineering |
Rollers are engineered for: |
1. Low friction |
2. High durability |
3. Stable grip |
4. Minimal slippage |
Materials may include: |
1. Rubber composites |
2. Silicone coatings |
3. Hardened metal cores |
|
4. Label Path Engineering |
4.1 Media Path Geometry |
The label path ensures: |
1. Stable movement |
2. Consistent tension |
3. Precise positioning at RFID encoding zone |
4.2 Path Stability Requirements |
Instability can lead to: |
1. RFID misalignment |
2. Print distortion |
3. Encoding failure |
4.3 Curvature Control |
Media must follow controlled curvature to prevent: |
1. Creasing |
2. Stretching |
3. Skewing |
|
5. Printhead Mechanical Assembly |
5.1 Printhead Mounting System |
The printhead is mounted using: |
1. Adjustable brackets |
2. Spring-loaded mechanisms |
3. Pressure balancing systems |
5.2 Printhead Pressure Control |
Proper pressure ensures: |
1. Consistent thermal transfer |
2. Uniform print density |
3. Accurate barcode edges |
Too much pressure causes: |
1. Printhead wear |
2. Media deformation |
Too little pressure causes: |
1. Faded printing |
2. Poor barcode readability |
5.3 Printhead Alignment Adjustment |
Fine adjustments control: |
1. Horizontal alignment |
2. Angular tilt |
3. Contact uniformity |
|
6. RFID Encoding Zone Mechanics |
6.1 Encoding Zone Positioning |
The RFID encoding zone must align: |
1. Antenna field |
2. RFID inlay |
3. Label position |
within millimeter-level accuracy. |
6.2 Stop-and-Go vs Continuous Motion |
Two main encoding approaches: |
A. Stop-and-Go Encoding |
* Label stops at encoding position |
* RF operation occurs |
* Then movement resumes |
B. Continuous Encoding |
* Label moves continuously |
* RF timing is precisely synchronized |
6.3 Mechanical Stability in Encoding Zone |
Mechanical vibration must be minimized to prevent: |
1. RF signal distortion |
2. Position drift |
3. Encoding errors |
|
7. Ribbon Transport Mechanism |
7.1 Ribbon Feed System |
Thermal transfer printers use ribbon systems including: |
1. Supply spool |
2. Take-up spool |
3. Ribbon path guides |
7.2 Ribbon Tension Control |
Maintaining correct tension prevents: |
1. Wrinkling |
2. Slippage |
3. Print distortion |
7.3 Ribbon Drive Synchronization |
Ribbon speed must match media speed exactly. |
7.4 Ribbon Slip Compensation |
Sensors detect and correct: |
1. Slack |
2. Over-tension |
3. Misalignment |
|
8. Cutting and Dispensing Systems |
8.1 Cutter Mechanisms |
Some RFID printers include automatic cutters: |
1. Rotary cutters |
2. Guillotine cutters |
3. Sliding blade cutters |
8.2 Cutter Precision Requirements |
Cutting systems must ensure: |
1. Clean edges |
2. No label tearing |
3. Consistent length |
8.3 Dispensing Systems |
Dispensers separate labels from backing liners. |
Used in: |
1. Apply-and-print systems |
2. Automated packaging lines |
|
9. Sensor Integration in Mechanical Systems |
9.1 Optical Sensors |
Used for: |
1. Label detection |
2. Gap detection |
3. Alignment verification |
9.2 Mechanical Limit Sensors |
Detect: |
1. Cover open status |
2. Media end |
3. Ribbon end |
9.3 RFID Zone Sensors |
Monitor RF activity and tag presence. |
9.4 Feedback Sensor Loops |
Sensors provide feedback to firmware for: |
1. Motion correction |
2. Alignment adjustment |
3. Error detection |
|
10. Vibration and Stability Engineering |
10.1 Sources of Vibration |
Vibration may originate from: |
1. Motors |
2. Gear systems |
3. External machinery |
4. Rapid media movement |
10.2 Vibration Isolation Systems |
Printers use: |
1. Rubber mounts |
2. Shock absorbers |
3. Dampening frames |
10.3 Structural Rigidity Design |
High-end printers use reinforced frames to minimize: |
1. Oscillation |
2. Resonance |
3. Mechanical drift |
|
11. Thermal Expansion Management |
11.1 Thermal Effects on Mechanics |
Heat from printheads causes: |
1. Expansion of components |
2. Alignment drift |
3. Mechanical stress |
11.2 Compensation Design |
Engineers use: |
1. Heat-resistant materials |
2. Expansion-tolerant structures |
3. Compensation algorithms |
11.3 Material Selection |
Common materials include: |
1. Aluminum alloys |
2. Steel composites |
3. High-temperature plastics |
|
12. Lubrication and Wear Control |
12.1 Mechanical Wear Issues |
Wear affects: |
1. Rollers |
2. Bearings |
3. Gears |
4. Feed mechanisms |
12.2 Lubrication Systems |
Lubricants reduce friction and extend life. |
Types: |
1. Grease-based |
2. Oil-based |
3. Dry lubrication coatings |
12.3 Maintenance Cycles |
Industrial systems require scheduled maintenance for: |
1. Roller replacement |
2. Bearing inspection |
3. Mechanical recalibration |
|
13. Gear Systems and Power Transmission |
13.1 Gear Train Design |
Gear systems transfer motor power to: |
1. Media rollers |
2. Ribbon spools |
3. Cutter systems |
13.2 Gear Precision Requirements |
Precision gears reduce: |
1. Backlash |
2. Positional error |
3. Vibration |
13.3 Belt Drive Systems |
Some systems use belts instead of gears for: |
1. Reduced noise |
2. Smoother motion |
3. Lower maintenance |
|
14. High-Speed Mechanical Operation |
14.1 Acceleration Dynamics |
Rapid acceleration requires careful control to prevent: |
1. Media slippage |
2. RFID misalignment |
14.2 Deceleration Control |
Controlled deceleration ensures: |
1. Precise stopping at encoding zone |
2. Stable print positioning |
14.3 Throughput Optimization |
Mechanical systems must balance: |
1. Speed |
2. Accuracy |
3. Stability |
|
15. Industrial Mechanical Durability |
15.1 Duty Cycle Engineering |
Industrial RFID printers are designed for: |
1. Continuous operation |
2. High-volume production |
3. Long operational lifetimes |
15.2 Component Fatigue Resistance |
Design considerations include: |
1. Stress distribution |
2. Material fatigue limits |
3. Wear resistance |
15.3 Environmental Durability |
Systems must withstand: |
1. Dust |
2. Heat |
3. Moisture |
4. Industrial vibration |
|
16. Mechanical Calibration Procedures |
16.1 Initial Mechanical Setup |
Includes: |
1. Roller alignment |
2. Printhead positioning |
3. Sensor calibration |
16.2 Ongoing Mechanical Adjustment |
Systems may self-adjust during operation to maintain: |
1. Accuracy |
2. Alignment |
3. Stability |
16.3 Service Calibration |
Technicians perform periodic recalibration of: |
1. Feed systems |
2. Cutter alignment |
3. Printhead pressure |
|
17. Robotics and Automation Integration |
17.1 Automated Label Handling |
RFID printers may integrate with: |
1. Robotic arms |
2. Conveyor systems |
3. Automated applicators |
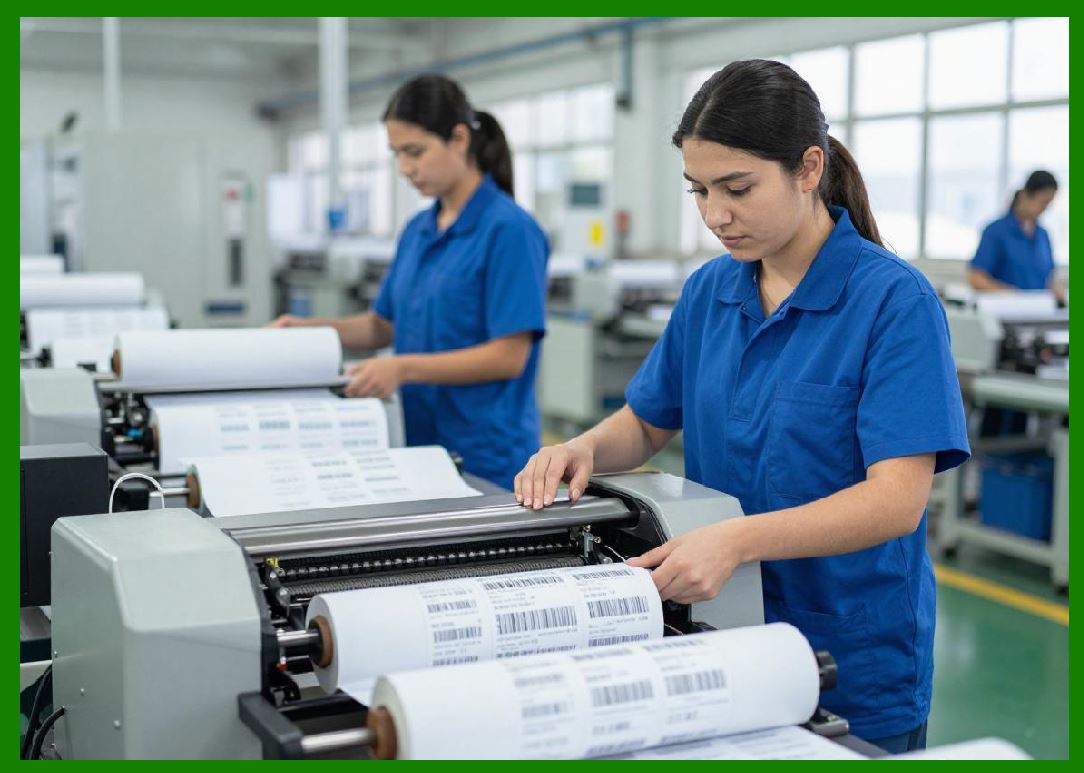
17.2 Inline Manufacturing Systems |
Printers are often embedded in production lines for: |
1. Real-time labeling |
2. RFID encoding |
3. Quality verification |
17.3 Smart Factory Integration |
Mechanical systems are coordinated with: |
1. Industrial IoT networks |
2. Centralized control systems |
3. AI-driven manufacturing systems |
|
18. Mechanical Failure Modes |
18.1 Common Mechanical Failures |
Include: |
1. Roller wear |
2. Belt degradation |
3. Gear misalignment |
4. Sensor displacement |
18.2 RFID-Related Mechanical Failures |
Specific to RFID systems: |
1. Encoding misalignment |
2. RF zone instability |
3. Label skew affecting antenna alignment |
18.3 Predictive Mechanical Failure Detection |
Advanced systems monitor: |
1. Vibration patterns |
2. Motor load |
3. Wear signatures |
|
19. Future Mechanical Engineering Trends |
19.1 Smart Mechanical Systems |
Future printers may include: |
1. Self-adjusting rollers |
2. Adaptive alignment systems |
3. Intelligent wear compensation |
19.2 Lightweight Composite Structures |
New materials will reduce: |
1. Weight |
2. Vibration |
3. Thermal expansion |
19.3 Self-Healing Materials |
Research explores materials capable of: |
1. Repairing micro-cracks |
2. Extending mechanical lifespan |
19.4 Fully Autonomous Mechanical Calibration |
Future systems may continuously self-optimize without human intervention. |
|
20. Integration Between Mechanical, RF, and Printing Systems |
20.1 System Synchronization |
Mechanical systems must synchronize with: |
1. RF encoding timing |
2. Thermal printing cycles |
3. Sensor feedback loops |
20.2 Unified Control Architecture |
All mechanical subsystems are controlled by: |
1. Embedded firmware |
2. Real-time operating systems |
3. Motion controllers |
20.3 System-Level Stability |
Overall system stability depends on perfect integration of: |
1. Mechanics |
2. Electronics |
3. RF systems |
4. Software control |
|
Detailed Technical Content Summary |
This Part provided a comprehensive technical explanation of the mechanical architecture, motion control systems, precision mechanics, and industrial build engineering of RFID-enabled barcode label printers. The article covered the structural design of printer frames, media transport systems, roller engineering, and printhead mounting mechanisms. |
Detailed analysis included RFID encoding zone mechanics, ribbon transport systems, cutter and dispensing mechanisms, sensor integration, vibration control, thermal expansion management, lubrication systems, gear and belt drive systems, and high-speed motion dynamics. |
The article also explored industrial durability requirements, mechanical calibration procedures, robotics integration, smart factory connectivity, and mechanical failure modes. Finally, future developments such as smart mechanical systems, composite structures, self-healing materials, and autonomous calibration technologies were discussed in depth. |
End of Part 11. |
 cs@easiersoft.com