Industrial Robot: Path Planning Algorithms |
Path planning is one of the most fundamental problems in robotics, especially in industrial applications where robots are often required to perform precise tasks in environments filled with constraints and potential obstacles. The purpose of path planning is to determine the best route for a robot to move from a start position to a goal position while avoiding obstacles and respecting physical limitations in the workspace. This process is integral to the efficiency and effectiveness of industrial robots, which are frequently tasked with repetitive, high-precision tasks in manufacturing, assembly, and packaging processes. |
In industrial environments, the workspace is typically constrained by machinery, tools, and sometimes other robots. This creates a dynamic, complex environment in which the robot must navigate, sometimes in tight spaces, with various factors influencing the path, such as time, energy consumption, and safety. |
|
1. Introduction to Path Planning in Industrial Robots |
Industrial robots are designed to handle a wide variety of tasks such as welding, painting, material handling, and assembly, often under strict operational constraints. One of the key aspects of their functioning is their ability to navigate the workspace efficiently. Path planning algorithms are crucial in determining the robot's movements while avoiding collisions with obstacles and adhering to operational constraints like velocity limits, acceleration, and joint limits. |
Path planning can be broken down into several key components: |
Start and Goal Configuration: The robot must know its initial position (start) and the target position (goal) within its workspace. These configurations define the boundary of the planning problem. |
Obstacles and Constraints: The robot must avoid obstacles within the workspace. These could be static (fixed objects) or dynamic (moving objects, including other robots). Constraints could also include the robot's kinematic limits and the presence of narrow paths or non-traversable regions. |
Optimization Criteria: In many industrial applications, efficiency is important. This could involve optimizing for the shortest path, minimizing energy consumption, or reducing the time required to complete the task. |
|
2. Types of Path Planning |
There are two main categories of path planning approaches: global and local. |
Global Path Planning: This type of path planning assumes that the entire workspace and all obstacles are known in advance. The algorithm computes a path from the start to the goal using the global map of the environment. It is particularly useful in environments that are static or when the robot is in a scenario where there is enough time and computational resources to process the entire environment. |
Local Path Planning: In contrast, local path planning algorithms operate in dynamic environments where obstacles and the robot's surroundings may change during operation. These algorithms typically adjust the robot's path in real-time based on the robot's immediate environment and local sensory data. |
|
3. Key Challenges in Industrial Robot Path Planning |
Industrial environments present several challenges for path planning algorithms: |
Complex Workspaces: Industrial settings are often cluttered with machinery, tools, and other obstacles, making path planning difficult. The robot must maneuver through these obstacles while avoiding collisions. |
Dynamic Obstacles: In environments with multiple robots, or where workers move around, the obstacles in the environment are not static. The robot must account for these dynamic elements during its planning phase. |
Robot Kinematics: Most industrial robots are not point masses; they have multiple joints and links that constrain their movement. Path planning algorithms must consider the robot's kinematic model, which includes joint limits, reachability, and other constraints. |
Coordination between Multiple Robots: In environments where multiple robots are operating simultaneously, path planning must also take into account the movements of other robots to prevent collisions and ensure smooth, coordinated operations. |
Workspace Constraints: These constraints could involve safety margins, velocity and acceleration limits, and limitations imposed by the design of the workspace or the robot itself. |
|
4. Path Planning Algorithms |
There are several types of algorithms used for path planning in industrial robots. These algorithms vary in terms of their computational complexity, suitability for different environments, and optimization capabilities. |
4.1. Graph-Based Algorithms |
Graph-based algorithms represent the workspace as a graph where nodes correspond to positions in the space, and edges represent the possible paths between those positions. The objective is to find a path from the start node to the goal node. |
Dijkstra's Algorithm: One of the most well-known graph-based algorithms. Dijkstra's algorithm finds the shortest path from the start position to the goal position by iteratively exploring nodes with the lowest known cost. The algorithm is guaranteed to find the shortest path, but it can be computationally expensive in large, complex environments. |
A (A-star) Algorithm*: A popular and widely used path-planning algorithm. It is an extension of Dijkstra's algorithm, which uses a heuristic to guide the search toward the goal more efficiently. The A* algorithm balances between exploration (discovering new nodes) and exploitation (choosing the best known path) by considering both the cost to reach a node and the estimated cost to the goal. |
The general idea of A* is to expand nodes based on the formula: |
f(n) = g(n) + h(n) |
Where: |
f(n) is the total estimated cost of the path through node n. |
g(n) is the cost from the start node to node n. |
h(n) is the heuristic estimate of the cost from node n to the goal. |
A* can be more computationally efficient than Dijkstra's algorithm by prioritizing paths that appear to be closer to the goal. |
4.2. Sampling-Based Algorithms |
Sampling-based algorithms are commonly used in high-dimensional spaces, such as those encountered with robotic arms or other multi-jointed robots. These algorithms generate random samples in the space and use these samples to construct a path. |
Probabilistic Roadmap Method (PRM): PRM builds a roadmap by randomly sampling the robot's configuration space, generating a graph of feasible configurations, and then connecting these configurations using collision-free paths. The algorithm is particularly efficient in high-dimensional spaces where graph-based methods might become intractable. |
Rapidly-exploring Random Tree (RRT): RRT is another popular sampling-based algorithm that builds a tree of paths by starting from the initial position and growing branches toward random points in the configuration space. RRT is particularly useful when the robot's configuration space is complex and difficult to model explicitly. A key advantage of RRT is its ability to rapidly explore large areas of the configuration space, making it ideal for navigating through complex environments. |
4.3. Optimization-Based Algorithms |
Optimization-based algorithms formulate the path planning problem as an optimization problem. The objective is to minimize (or maximize) a certain cost function while satisfying the constraints of the problem, such as avoiding obstacles and respecting the robot's kinematic limits. |
Trajectory Optimization: This approach involves optimizing a trajectory over time, considering the robot's dynamics and kinematic constraints. The goal is to find the path that minimizes energy consumption or time while satisfying all constraints. These algorithms typically involve solving non-linear optimization problems, which can be computationally intensive. |
Potential Fields: In this approach, the robot is treated as a particle subject to forces that guide its movement. Attractive forces pull the robot toward the goal, while repulsive forces push the robot away from obstacles. This method can be effective in simple environments but may struggle in more complex or cluttered spaces due to the risk of local minima, where the robot becomes trapped in a suboptimal path. |
4.4. Hybrid Algorithms |
In some industrial applications, a hybrid approach combining various algorithms is used to balance efficiency and reliability. For example, a combination of A* for global planning and RRT for local planning can be used to generate a robust and efficient path in complex environments. |
Another example is a hybrid system that uses optimization-based methods for fine-tuning the trajectory once a rough path is generated by a graph-based or sampling-based method. |
|
5. Applications of Path Planning Algorithms in Industrial Robotics |
Industrial robots are used in a wide range of applications, and path planning is a critical component in all of them. Below are some specific applications where path planning algorithms play a vital role: |
5.1. Material Handling and Transport |
In automated material handling systems, robots are used to move goods between different parts of the factory or warehouse. Path planning ensures that robots can efficiently and safely navigate around obstacles, such as shelves, workers, and other robots, while optimizing their path for time or energy. |
5.2. Welding and Painting |
In industrial welding and painting applications, robots are often tasked with moving along predefined paths to apply welds or paint coatings. Path planning ensures that the robot follows an optimal route, avoids obstacles, and adheres to specific speed and precision requirements. |
5.3. Assembly and Packaging |
In assembly lines or packaging systems, robots must place or assemble parts with high accuracy and speed. Path planning algorithms are used to ensure that the robot moves efficiently and with minimal interference from other robots or obstacles. |
5.4. Collaborative Multi-Robot Systems |
In modern factories, multiple robots often work together to perform complex tasks. Path planning is critical in these collaborative environments to prevent collisions and coordinate movements effectively. Multi-robot path planning algorithms take into account the movement of all robots in the workspace, ensuring that they work in harmony without any risk of interference. |
|
6. Conclusion |
Path planning algorithms are an essential component of industrial robot functionality. They enable robots to perform complex tasks in dynamic and constrained environments, from material handling to assembly, welding, and packaging. These algorithms ensure that robots can move efficiently and safely, avoiding obstacles and adhering to the constraints of the workspace. As industrial robots become more advanced and are deployed in increasingly complex environments, the need for more sophisticated path planning methods will continue to grow. The development of more efficient, adaptive, and collaborative path planning algorithms will play a significant role in the future of industrial robotics. |
|
What new technologies will be related to this in the future? |
1. Introduction to Future Technologies in Industrial Robot Path Planning |
The rapid development of new technologies in the field of robotics promises to significantly impact path planning algorithms in industrial applications. As robots become more advanced and are deployed in increasingly complex and dynamic environments, new technologies will enhance their ability to plan and execute efficient, collision-free paths. These technologies will not only improve the effectiveness and safety of industrial robots but also expand their capabilities, enabling them to perform more tasks with greater autonomy, precision, and coordination. |
In the future, several emerging technologies are expected to play a crucial role in the advancement of industrial robot path planning. These include artificial intelligence (AI) and machine learning (ML), real-time data processing and sensor technologies, multi-robot coordination, 5G and edge computing, quantum computing, and advanced simulation environments. |
|
2. Artificial Intelligence (AI) and Machine Learning (ML) in Path Planning |
Artificial Intelligence (AI) and Machine Learning (ML) are poised to revolutionize path planning in industrial robotics by making robots more adaptive, intelligent, and autonomous. The future of industrial robot path planning will leverage AI and ML to handle increasingly complex, unstructured, and dynamic environments. |
2.1. Reinforcement Learning (RL) for Dynamic Path Planning |
One of the most promising applications of ML in path planning is reinforcement learning (RL), which enables robots to learn optimal behaviors through trial and error. In reinforcement learning, a robot learns to navigate by receiving feedback from its environment (rewards or penalties) as it explores different paths. This approach is particularly useful in environments with changing obstacles, where traditional methods like A* or Dijkstra's might struggle. |
For instance, a robot performing material handling or assembly in a factory can use RL to continuously improve its path planning strategies by adapting to changes such as the movement of other robots, workers, or dynamic obstacles in the workspace. Over time, the robot learns not only the shortest or safest paths but also the most efficient ones considering factors such as energy consumption, speed, and operational costs. |
2.2. Deep Learning for Perception and Path Prediction |
Deep learning, a subset of AI, is particularly useful in enabling robots to understand and interpret their environment through sensor data. Using convolutional neural networks (CNNs) and other deep learning models, robots can process visual, LiDAR, and other sensory data to recognize obstacles, predict future movements of dynamic objects, and identify safe paths. |
For example, deep learning can be employed to enhance the robot's ability to understand and predict the behavior of workers or other robots, enabling better real-time adjustments to planned paths. The ability to make informed predictions will reduce the likelihood of collisions and improve the efficiency of multi-robot systems in complex environments. |
|
3. Real-Time Data Processing and Sensor Technologies |
Advancements in sensors and real-time data processing will significantly improve the ability of robots to plan paths dynamically, especially in environments with moving obstacles or rapidly changing conditions. The integration of advanced sensors such as 3D LiDAR, ultrasonic sensors, and high-definition cameras allows robots to create detailed maps of their surroundings in real time. |
3.1. 3D LiDAR and Computer Vision for Real-Time Mapping |
3D LiDAR (Light Detection and Ranging) is a technology that generates detailed three-dimensional point clouds of the robot's environment. When combined with advanced computer vision techniques, LiDAR can help robots detect and recognize obstacles with high accuracy, even in cluttered industrial environments. |
These sensors will allow robots to build more accurate, up-to-date maps of their surroundings. By processing sensor data in real-time, robots can make quick adjustments to their path as they detect changes in the environment, such as the movement of other robots, workers, or machines. This dynamic obstacle avoidance is critical for environments like warehouses, production lines, and factories where conditions change frequently. |
3.2. Sensor Fusion for Enhanced Decision Making |
Sensor fusion refers to the combination of data from multiple sensors to create a more complete and accurate picture of the environment. By combining data from LiDAR, cameras, ultrasonic sensors, and other modalities, robots can generate more reliable models of their workspace. Sensor fusion enhances path planning by improving the robot's ability to detect obstacles, even those that may be partially obstructed or outside of the robot's direct line of sight. |
This improved perception will allow robots to make better decisions about their movements in real-time, optimizing their paths for efficiency and safety. It also makes it easier to integrate multiple robots into the same workspace without collisions, as each robot can constantly monitor its environment and communicate with others. |
|
4. Multi-Robot Coordination and Collaborative Path Planning |
As more factories adopt multi-robot systems for increased productivity and flexibility, coordinating the movements of multiple robots becomes crucial. Multi-robot coordination allows several robots to collaborate seamlessly, handling more complex tasks and reducing idle time by optimizing their collective movements. |
4.1. Decentralized Path Planning Algorithms |
In the future, decentralized path planning algorithms will become more advanced. These algorithms allow multiple robots to plan their paths independently, with limited centralized control. This is particularly important in dynamic, large-scale industrial environments where real-time coordination and autonomy are necessary. |
Decentralized path planning techniques, such as Distributed Model Predictive Control (DMPC) or auction-based algorithms, allow robots to make local decisions about their paths, while still considering the movements and goals of other robots. This approach reduces computational overhead and can lead to faster response times when changes in the environment occur. |
4.2. Swarm Robotics for Collaborative Tasks |
Swarm robotics, inspired by the collective behavior of insects like ants and bees, allows a group of robots to work together to achieve a shared goal. Swarm robotics is especially useful for tasks like warehouse management, where robots need to pick up and transport items efficiently without getting in each other's way. |
In swarm robotics, path planning is not based on an individual robot's optimal path but on the collective optimization of the entire system. Each robot works independently but communicates with others to adjust their paths dynamically. This approach enables high levels of parallelism and adaptability, which can increase productivity in industrial environments. |
|
5. 5G and Edge Computing in Industrial Robot Path Planning |
The advent of 5G and edge computing technologies will provide the high-speed, low-latency communication necessary for real-time coordination and decision-making in industrial robots. |
5.1. 5G for Low-Latency Communication |
5G technology offers much faster communication speeds and lower latency compared to previous generations of mobile networks. In an industrial setting, where multiple robots are working in close proximity, low-latency communication is crucial for enabling real-time path planning, obstacle detection, and collision avoidance. Robots will be able to share information about their positions, velocities, and trajectories instantaneously, ensuring that path planning is optimized for the entire workspace. |
5.2. Edge Computing for Real-Time Processing |
Edge computing refers to the practice of processing data closer to where it is generated, rather than sending it to a central cloud server. By leveraging edge computing, industrial robots can process sensor data, execute algorithms, and make decisions on-site without relying on cloud-based systems. |
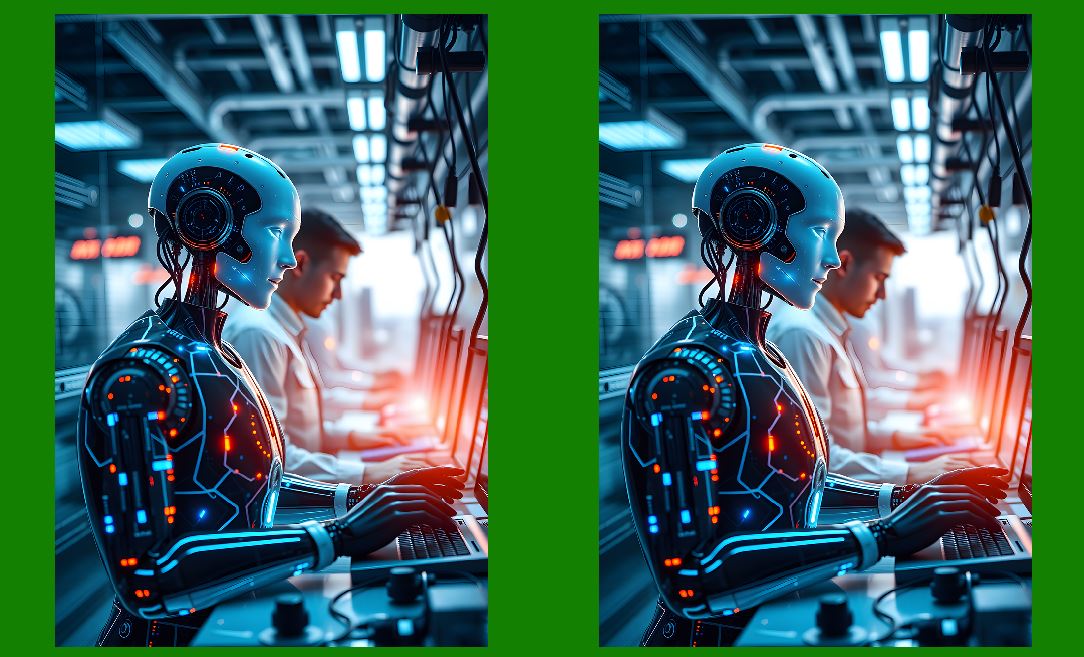
This capability is crucial for real-time path planning, as it ensures that robots can adjust their paths without waiting for external processing. For example, an industrial robot might need to avoid a moving obstacle immediately after detecting it, and edge computing allows this decision to be made without delay. |
|
6. Quantum Computing and Optimization for Path Planning |
Quantum computing is an emerging field that could have a transformative impact on path planning algorithms. Quantum computers use quantum bits (qubits) instead of traditional bits, allowing them to process certain types of problems much more efficiently than classical computers. |
6.1. Quantum Algorithms for Optimization |
Many path planning algorithms, such as those used in robot motion planning and multi-robot coordination, rely on optimization techniques to find the most efficient path. Quantum computing could significantly speed up optimization tasks by solving complex problems in a fraction of the time required by classical computers. For example, quantum algorithms like the Quantum Approximate Optimization Algorithm (QAOA) might one day be used to optimize trajectories in high-dimensional spaces or solve NP-hard path planning problems much faster. |
6.2. Quantum Machine Learning for Path Prediction |
Quantum machine learning could further enhance robot decision-making. By using quantum models, robots may be able to learn faster and more efficiently, improving their ability to predict the best path to take in complex, dynamic environments. The combination of quantum computing and machine learning could lead to path planning systems that are both highly adaptive and computationally efficient. |
|
7. Advanced Simulation Environments for Path Planning Testing |
In the future, the use of sophisticated simulation environments for testing path planning algorithms will become even more critical. Advanced simulations will allow for the testing of path planning algorithms in virtual environments before deploying them in the real world, reducing the risk of failure and improving efficiency. |
7.1. Digital Twin Technology |
Digital twins are virtual replicas of physical systems, such as industrial robots, production lines, and entire factories. These digital twins can simulate the behavior of robots and their interactions with the environment in real-time, providing valuable insights into how path planning algorithms will perform under various conditions. |
By using digital twins, engineers can optimize path planning algorithms before implementing them in the real world, saving time and resources. Digital twins also allow for continuous monitoring and adjustments of path planning in live systems, ensuring that robots perform optimally throughout their operations. |
|
8. Conclusion |
The future of industrial robot path planning will be shaped by a variety of emerging technologies that will enhance the robot's ability to navigate complex environments with greater autonomy, efficiency, and safety. Artificial intelligence, machine learning, real-time data processing, multi-robot coordination, and quantum computing are just a few of the innovations that will drive the next generation of industrial robotics. |
As these technologies continue to evolve, industrial robots will become more capable of adapting to dynamic workspaces, optimizing their movements in real-time, and collaborating seamlessly with other robots and humans. The resulting improvements in path planning will make industrial robots even more valuable in manufacturing, logistics, and other sectors, enabling the creation of smarter, more efficient factories. |
 cs@easiersoft.com